Sunny Fang / Engineering Portfolio

Engineering Portfolio

Sunny Fang.

First Year Engineering → Mechanical Engineering

I am Sunny Fang, a student at Purdue University and an aspiring mechanical engineer based in Fremont, CA.

In my spare time I enjoy working on passion projects, reading web novels, and playing video games with friends!

Projects

05 RECORDS
Custom CoreXY 3D printer

Personal Projects

Custom CoreXY 3D Printer

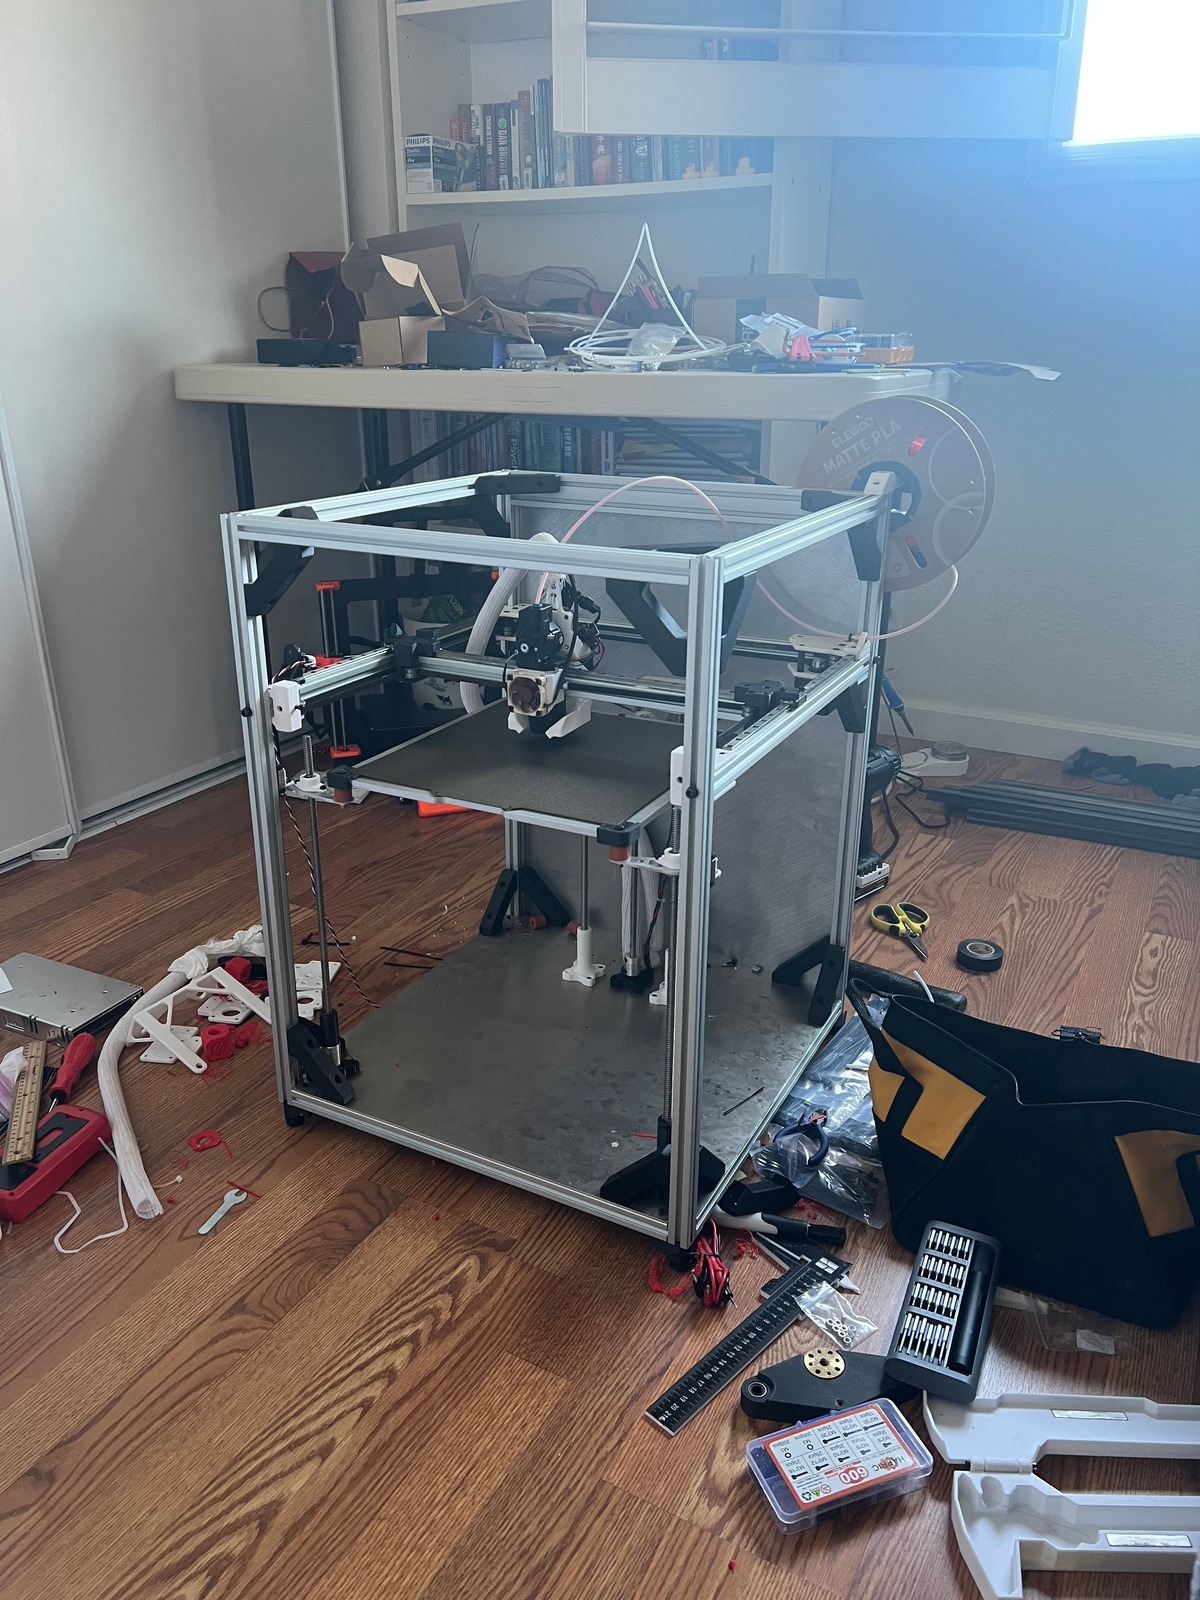
I decided to try my hand at designing my own CoreXY printer instead of just buying one. I first modeled the printer in the computer-aided design (CAD) program Onshape. I took inspiration from the Voron 2.4 and Trident and the RatRig vCore 4 3D printers, which are popular open-source CoreXY designs.
Team 9470 East Bay Regional REEFSCAPE robot

2025 REEFSCAPE

Team 9470 - REEFSCAPE

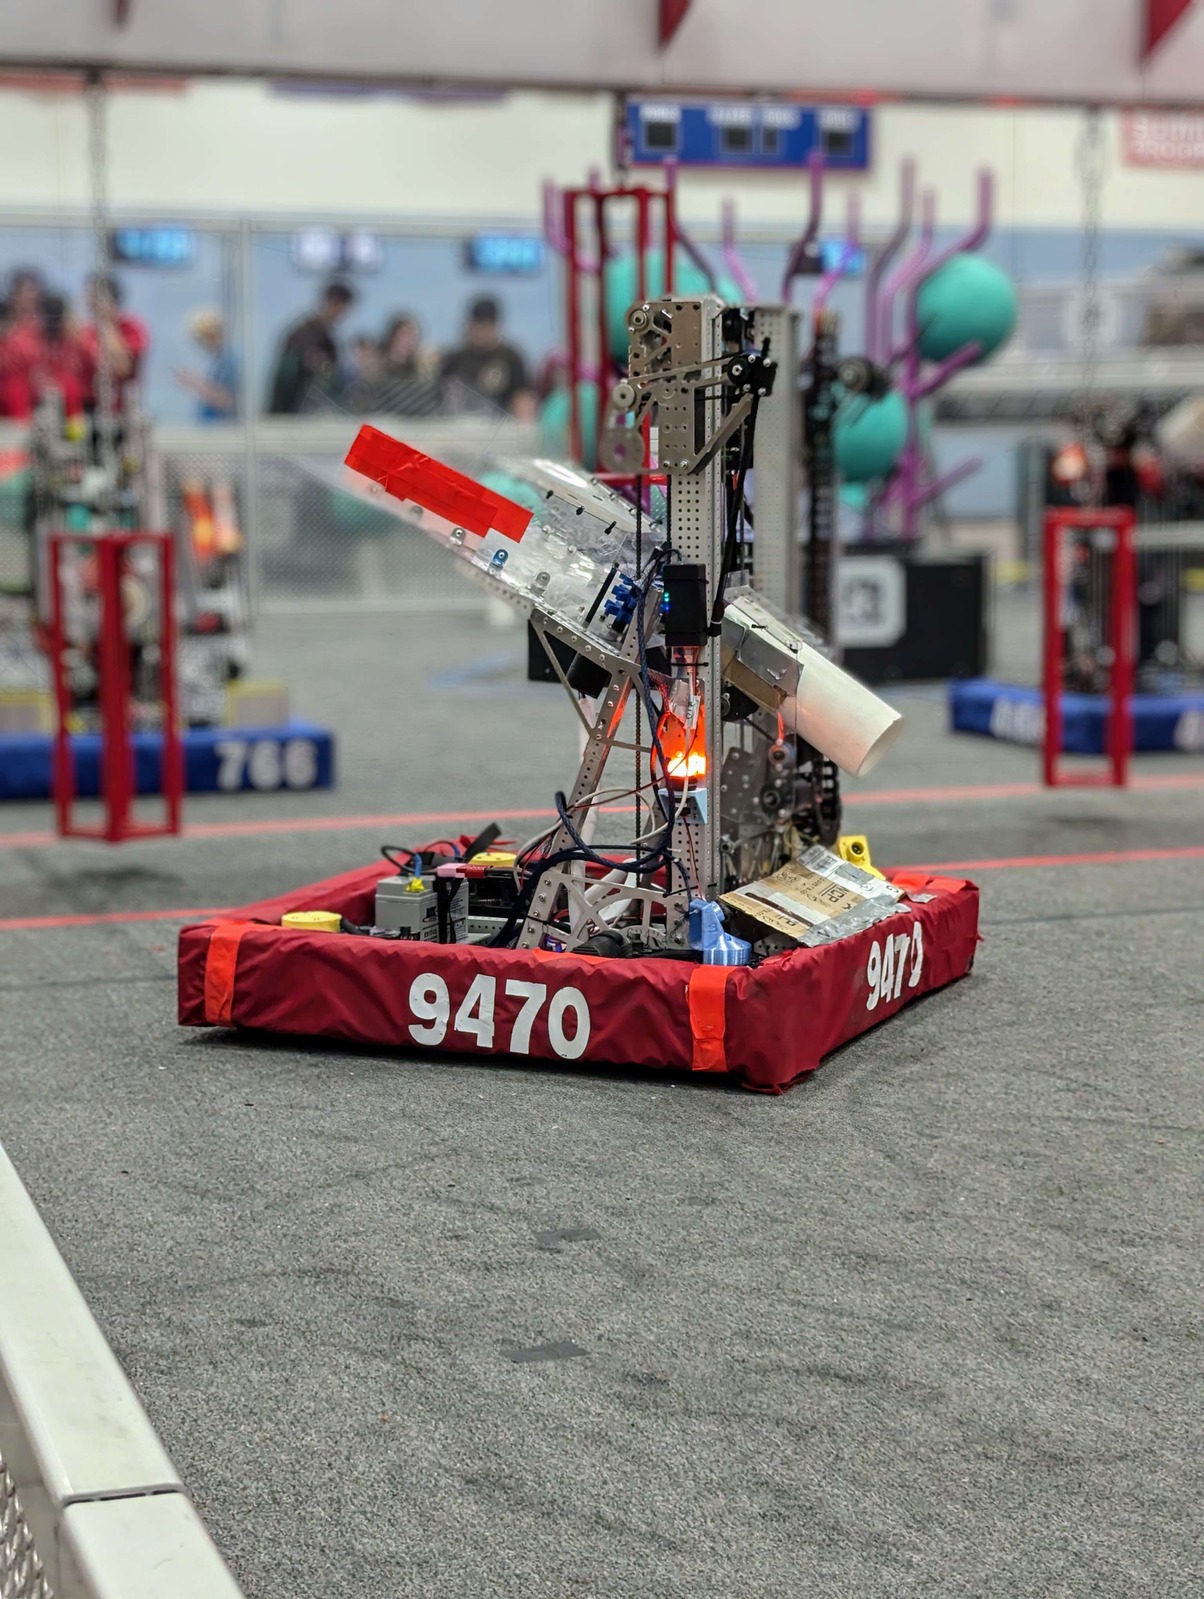
After Pinnacles, we decided to rebuild from a top-heavy robot to a more grounded robot that fully specialized in coral. After EBR, we decided to modify the funnel to add an endgame mechanism while keeping the coral scoring at the same level. Instead of the usual cascade elevator and funnel, we used a more complex continuous elevator with a ground intake.

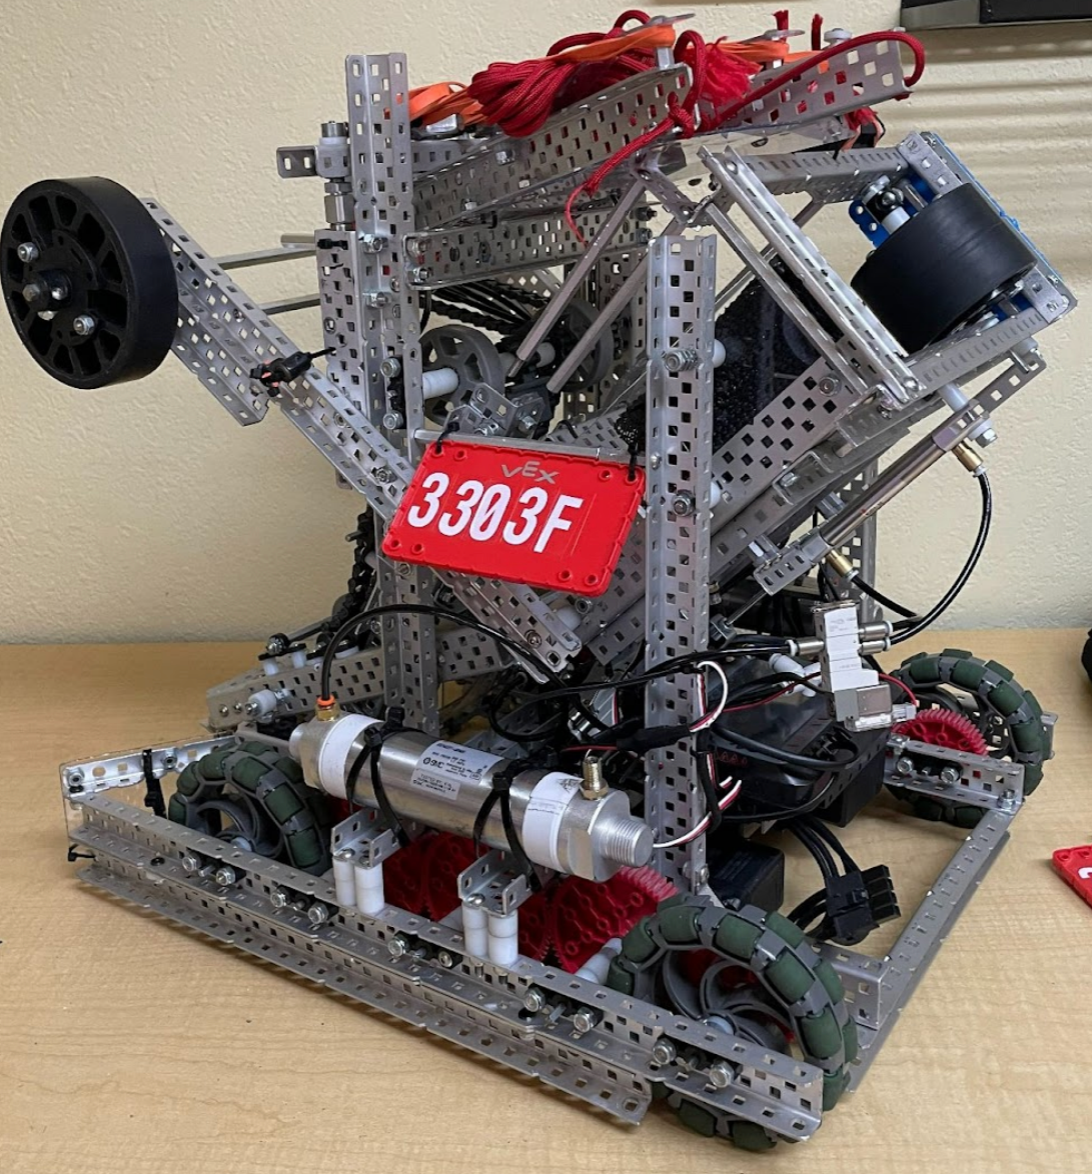
Team 3303F Spin Up robot

2022-2023 Spin Up

3303F - Spin Up

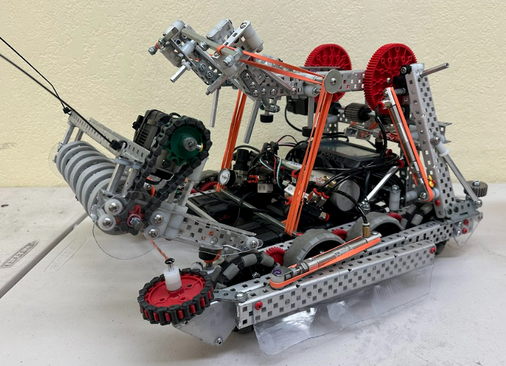
In VEX Spin Up, the objective was to score yellow foam disks into a disk golf-style goal and spin rollers on two opposite corners to the color of their alliance. In the last 15 seconds, robots could expand infinitely in the horizontal direction to contact as many tiles as possible for additional points. Overall, an effective robot able to play all aspects of the game, but suffered from a lack of design planning (free built, no CAD), and autonomous performance was lackluster due to not having an accurate positioning system (e.g. odometry).

Team 3303F in-season Over Under robot

2023-2024 Over Under

3303F - Over Under

In VEX Over Under, the objective was to score triangular balls (triballs) into goals. Overall an effective robot capable of playing all aspects of the game, but had issues with the pneumatics being too weak. Additionally, we did not have enough time to properly refine autonomous routines for the state competition.

Team 3457F High Stakes robot

2024-2025 High Stakes

3457F - High Stakes

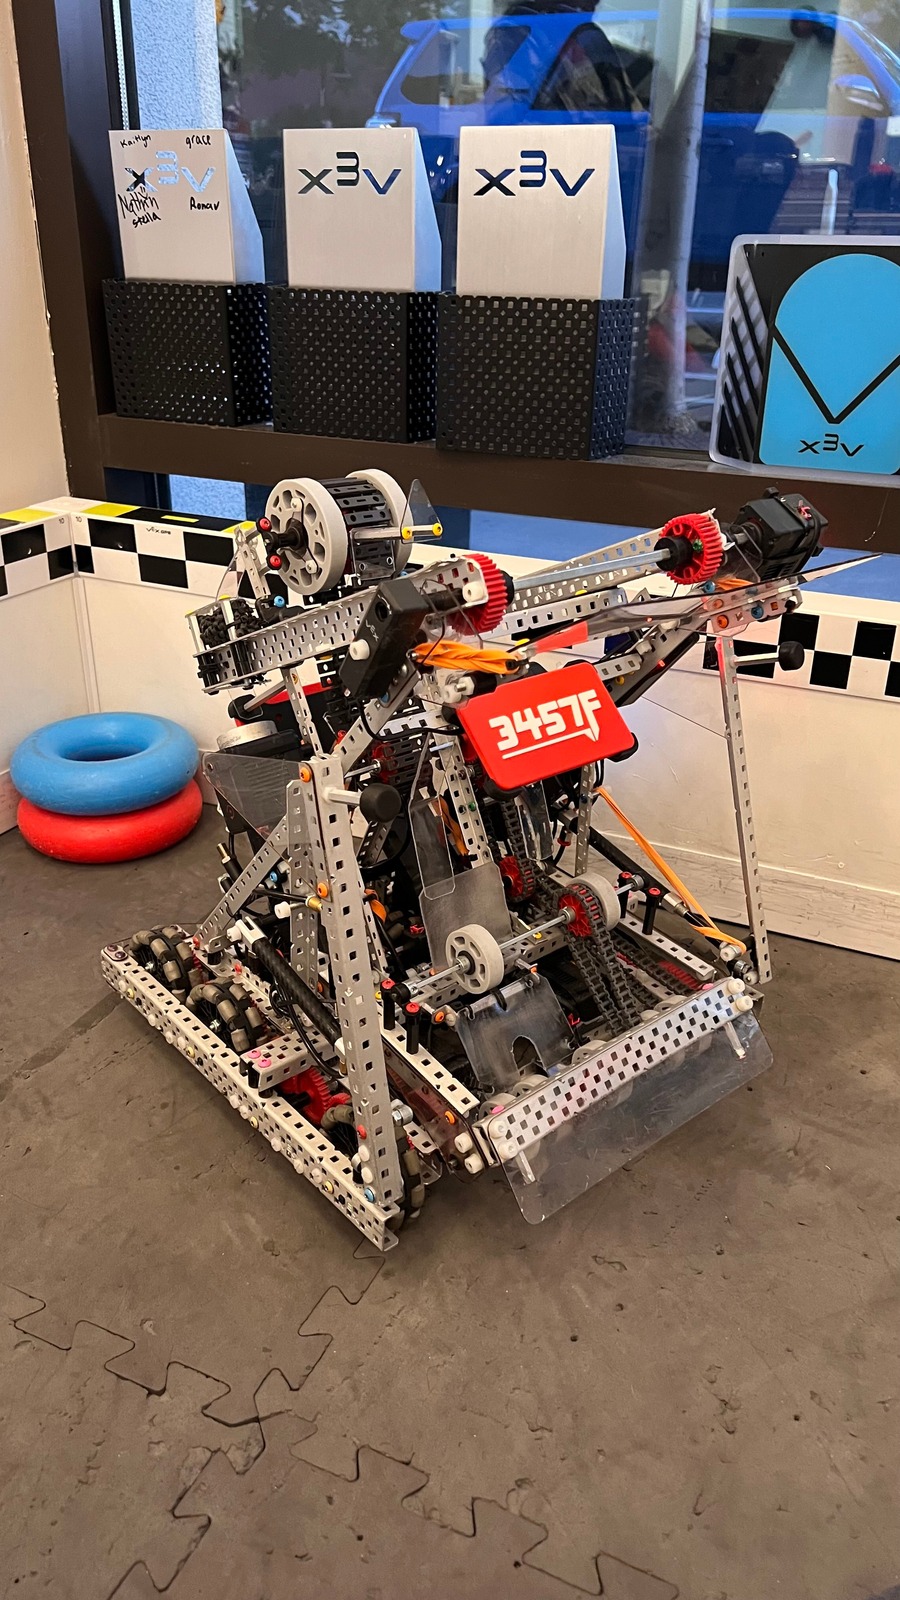
In VEX High Stakes, the objective was to score rings onto yellow poles (stakes). An effective robot that is able to score rings and contest stakes extremely well. For this robot, we stuck with a single design instead of constantly rebuilding like the previous year, which allowed us to properly refine autons and let the driver get practice.

Work Experience

ROBOLABS VRC, Fremont, CA

Sept. 2022 – August 2026

Instructor, Lead Mechanical Engineer, Programmer

  • Harness the engineering design process and rapid prototyping to design nationally recognized competitive robots in Team 3457F; rank in the top 5% at Create U.S. Open and reach Division Quarterfinals at the VEX World Championship
  • Experience in Fusion 360, Solidworks, Onshape to create assemblies of hundreds of components
  • Taught 50+ students the fundamentals of engineering and programming on the VEX Robotics platform across an 8-week summer program
  • Mentoring multiple VEX teams for mechanical design and software implementations
  • Worked as a paid instructor from Aug. 2025 to Aug. 2026

Urbot Robotics, San Jose, CA

June 2025 – August 2025

Software Intern

  • Developed Python software solutions for the teleoperation of complex 6-DOF robots
  • Utilized imitation learning and inverse kinematics to operate hotel/restaurant service robots
  • Worked with industry standards such as OpenCV, Dynamixel servos, and LeRobot machine learning

School Involvement

Purdue Electric Racing, West Lafayette, IN

August 2026 – Present

Aero Subteam

  • Learning aero theory for automotive design, creating airfoils using surface modeling in NX
  • Created an undertray for PER onboarding with rear diffusers and venturis

IEEE Motorsports, West Lafayette, IN

Sept. 2026 – Present

Mechanical Subteam

  • Working on a go-kart-style vehicle for Purdue ev-Grand Prix and Autonomous Karting Series
  • Collaborating in a 3-person team to create an RC car with Ackermann steering geometry using 3D printing and Fusion

Awards

Skills

Contact

(510) 493-0941

fang467@purdue.edu

linkedin.com/in/sunny-fang-1144993a8/

Back to top ↑