In VEX High Stakes, the objective was to score rings onto yellow poles (stakes). Stakes were located on the walls and on mobile goals (mogo), which were heavy bases that could be moved around and clamped onto by a robot. At the end of the match, robots would elevate themselves on the ladder in the center of the field for additional points.
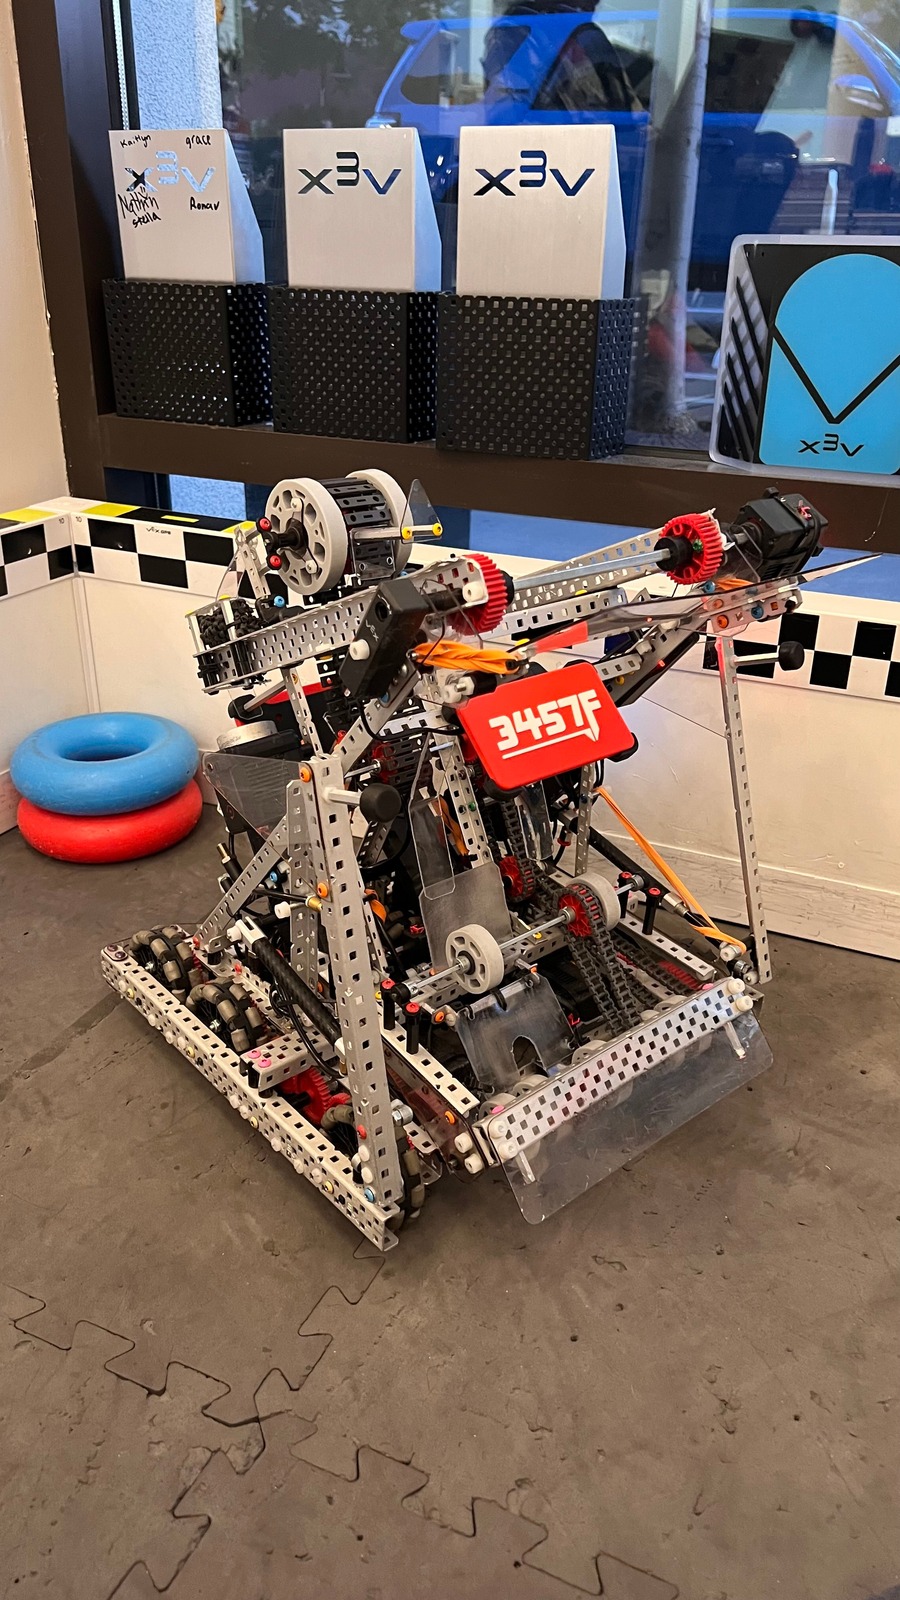
Specs:
- 450 rpm drivetrain with 6 motors
- 600 rpm intake with 1 motor
- 100 rpm wall stake mechanism
- 3D-printed magnetic license plates
- Pneumatic mogo clamp
An effective robot that is able to score rings and contest stakes extremely well. For this robot, we stuck with a single design instead of constantly rebuilding like the previous year, which allowed us to properly refine autons and let the driver get practice.