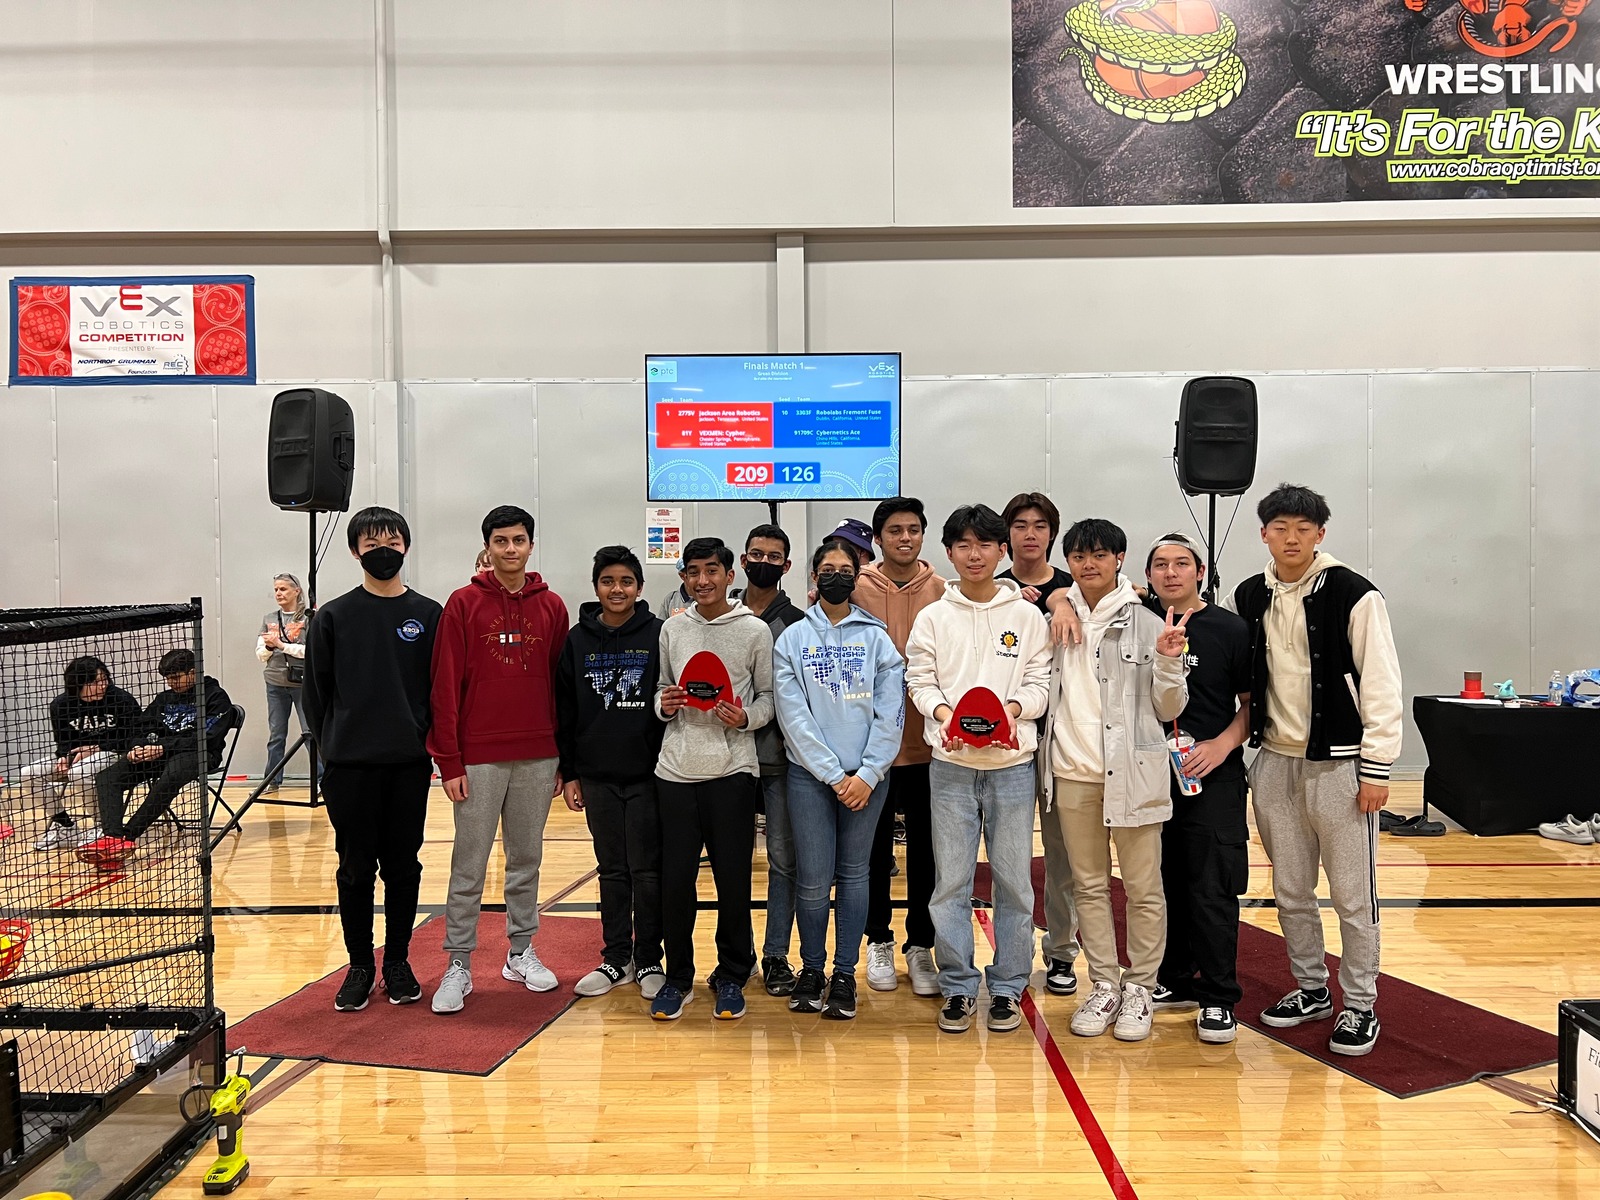
In VEX Spin Up, the objective was to score yellow foam disks into a disk golf-style goal and spin rollers on two opposite corners to the color of their alliance. In the last 15 seconds, robots could expand infinitely in the horizontal direction to contact as many tiles as possible for additional points.
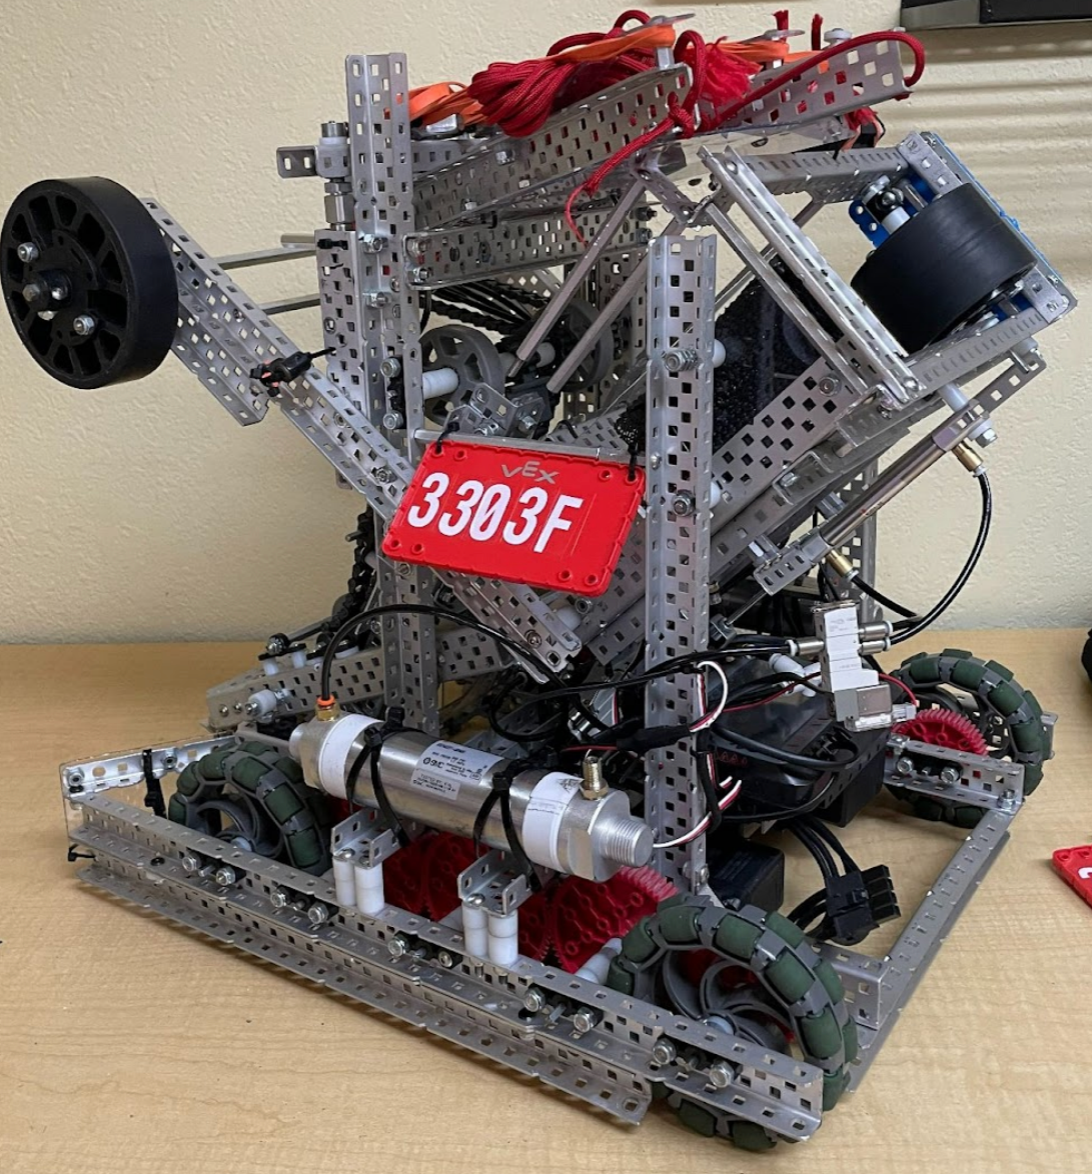
Specs:
- 6-wheel drivetrain, 4 in wheels
- 3600 rpm flywheel
- 4-string expansion, able to cover the entire field when shot from the corner
Overall, an effective robot able to play all aspects of the game, but suffered from a lack of design planning (free built, no CAD), and autonomous performance was lackluster due to not having an accurate positioning system (e.g. odometry).